Haolei Tong

Hey! This is Haolei Tong. I am currently a PhD student at the IPS Lab, University of Augsburg, under the supervision of Prof. Dr. Jörg-Dieter Stückler.

My research focuses on robot learning, with particular interests in bimanual manipulation and applications in industrial manufacturing.

Previously, I worked at Neura Robotics GmbH, focusing on imitation learning, vision-language-action (VLA) models, and bimanual manipulation.

I hold a master's degree in Autonomous Systems and Robotics from TU Darmstadt. I completed my master's thesis at the PEARL Lab, under the supervision of Prof. Georgia Chalvatzaki.

Additionally, I am a Formula 1 fan, and in my free time, I enjoy cycling.

Email  /  CV  /  Github  /  Google Scholar  /  LinkedIn

profile photo
Publications
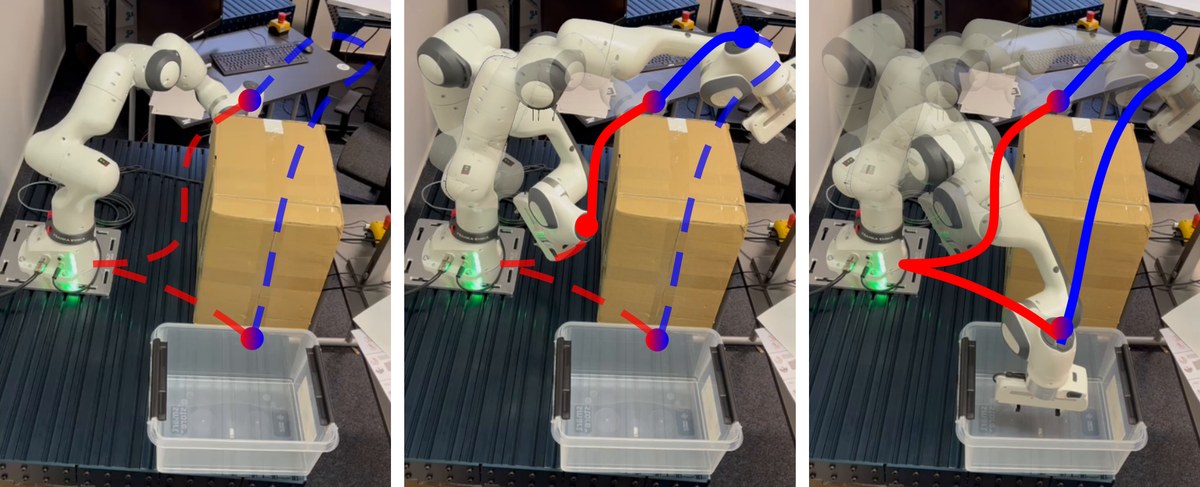
Adaptive Diffusion Constrained Sampling for Bimanual Robot Manipulation
Haolei Tong, Yuezhe Zhang, Sophie Lueth, Georgia Chalvatzaki
IEEE International Conference on Robotics and Automation (ICRA), 2026
paper / website

Find Something You Can't Do: Agentic Real-World Reinforcement Learning for Self-Improving VLA Models
Yuan Fang*, Zechu Li*, Haolei Tong, Puze Liu, Georgia Chalvatzaki
arXiv, 2026  (*equal contribution)
paper / website / code

Constrained GP Motion Planning Constrained Gaussian Process Motion Planning via Stein Variational Newton Inference
Jiayun Li, Kay Pompetzki, An Thai Le, Haolei Tong, Jan Peters, Georgia Chalvatzaki
arXiv, 2025
paper

Projects
Multi-Robot Pick and Place
Haolei Tong
Lab project, 2024
blog / code


paper notes

Feel free to steal this website's source code.